powered exoskeleton technology
How Powered Exoskeleton Technology Is Transforming Labor
Discover how powered exoskeleton technology enhances physical labor across industrial, rescue, and military sectors while driving battery innovations.
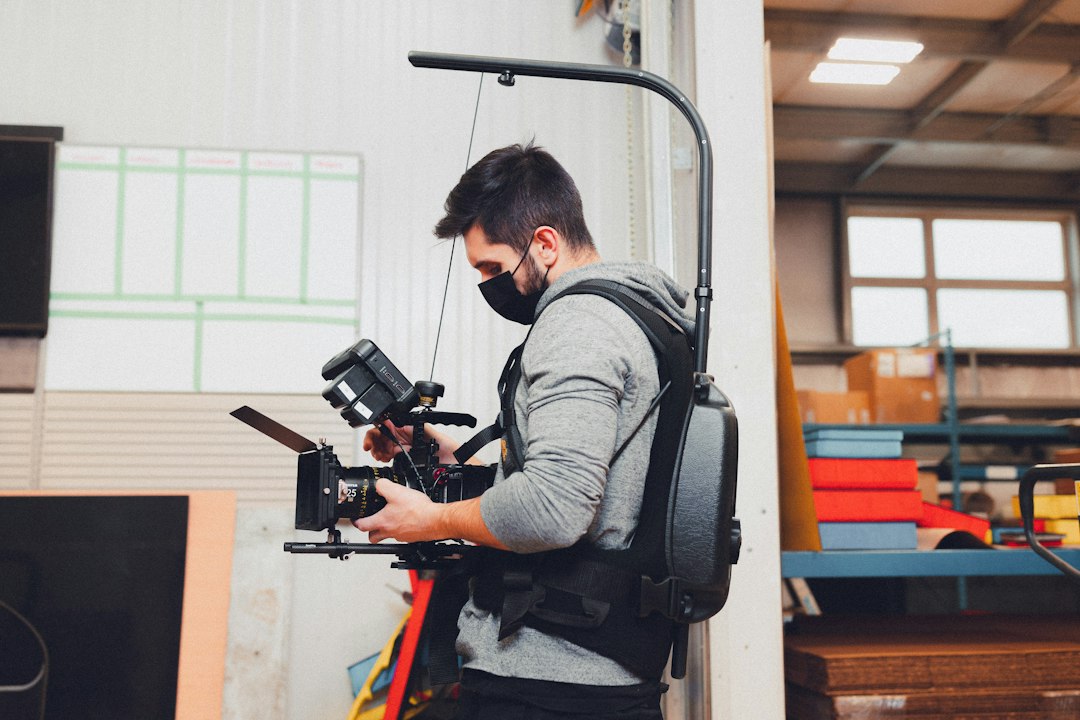
Powered exoskeleton technology is transitioning from experimental laboratory prototypes into commercial deployment across manufacturing logistics, emergency services, and defense sectors. Fueled by advancements in electric actuator systems, sensor miniaturization, and onboard algorithmic controls, these wearable mechanical frames enhance human physical endurance and structural load management. By augmenting lower-body and upper-body strength, wearable robotics reduce physical fatigue, lower work-related injury rates, and extend operational stamina in high-stress environments.
While early iterations were primarily restricted to clinical rehabilitation settings, the modern commercial landscape reflects broader enterprise adoption. Commercial estimates suggest the global market value could expand significantly over the next decade as hardware costs decline and power efficiency improves.
Commercial Deployment Across Key Enterprise Sectors
The integration of industrial exoskeletons has steadily accelerated as enterprise managers seek to mitigate chronic physical strain among workers performing repetitive lifting or overhead assembly.
Industrial Manufacturing and Logistics
Major automotive manufacturers and aerospace firms have integrated passive and active overhead support frames into assembly lines. In high-volume distribution centers, motorized back and shoulder support systems help workers move heavy cargo, directly targeting lower back strain—one of the leading causes of workplace disability claims globally.
Search and Rescue Operations
Field operations in rugged terrain present unique challenges for rescue teams carrying heavy survival gear and medical equipment. Emergency crews in North America and Western Europe have begun testing hip-and-leg assistance frameworks during backcountry operations. These motorized lower-body units absorb peak impacts during uphill ascents and downhill descents, allowing rescuers to maintain higher speed and stamina during urgent search missions.
Defense and Tactical Logistics
Military organizations are actively evaluating lower-body support systems for frontline logistics. Recent field usage highlights how soldiers handling artillery shells and heavy munitions benefit from active hip-flexion units. The continuous mechanical support allows personnel to shift heavy payloads faster while minimizing muscle exhaustion over extended operational shifts.
Mechanical Architecture: How Modern Systems Power Human Motion
At its technical core, powered exoskeleton technology relies on an intricate balance between structural ergonomics and rapid sensor feedback loops. These devices operate as human-machine hybrid platforms, sharing mechanical loads directly with the user's skeletal frame.
An active wearable frame generally comprises a rigid or semi-rigid chassis constructed from lightweight aluminum alloys, carbon fiber, or high-density polymers. This structure fastens to key points on the torso, waist, and limbs. Electric motors—known as actuators—are strategically positioned near natural body joints, such as the hips, knees, or shoulders.
Sensor Calibration and Adaptive Control
Modern units continuously monitor user movement through integrated inertial measurement units (IMUs), force sensors, and strain gauges. The onboard microcontroller processes these motion vectors in real time to adjust power delivery based on three primary control modes:
- Power Augmentation Mode: Generates continuous mechanical force to multiply the operator's natural strength, ideal for lifting heavy industrial cargo or military artillery.
- Assist-as-Needed Mode: Monitors the user's motion and applies supplementary torque only when it detects physical strain or velocity degradation. This setting is widely used in orthopedic rehabilitation.
- Full Robotic Control Mode: Guides the user's limbs through pre-programmed trajectory paths, offering complete motion replacement for individuals suffering from severe neurological or spinal injuries.
Advanced algorithmic models continuously evaluate stride frequency, ground inclination, and user acceleration. If an operator breaks into a run or stumbles on uneven terrain, the control system dynamically alters actuator timing to prevent falls and optimize torque delivery.
Technical Bottlenecks Hindering Widespread Adoption
Despite clear operational advantages, mechanical engineers face several physical constraints that prevent universal adoption across all manual industries.
Power Density and Battery Mass
The primary limitation of high-performance wearable robotics remains energy storage. High-torque electric actuators demand substantial energy, necessitating heavy lithium-ion battery packs. Adding excessive battery weight to the user's chassis creates a diminishing return, where the frame must expend a significant portion of its generated energy simply carrying its own power source. Until next-generation battery chemistries achieve higher energy densities, runtime remains capped at a few hours of intensive active use.
Human-Machine Control Interfaces
Current systems rely almost exclusively on reactive biomechanical sensors that detect physical movement after a muscle group begins to contract. This introduces a slight millisecond delay between human intent and robotic response. Researchers are actively pursuing direct biological interfaces, such as surface electromyography (sEMG) to read muscle electrical signals, or non-invasive neural interfaces. However, these solutions currently require complex, user-specific calibration and are susceptible to signal noise from sweat and environmental interference.
The Hardware Convergence With Humanoid Robotics
The supply chain for wearable mechanical assistance is directly benefiting from the massive capital investments currently pouring into humanoid robotics. Both sectors require highly specialized, compact components:
- Frameless Brushless Motors: High-torque density motors that fit within narrow joint envelopes.
- Harmonic Drive Gearboxes: Compact strain-wave gearing systems that deliver high gear ratios without mechanical backlash.
- Advanced Battery Management Systems (BMS): High-discharge power electronics optimized for variable torque demands.
As global manufacturing scales production for bipedal enterprise robots, component prices for identical motor drives and joint actuators are falling. This hardware convergence is drastically lowering the bill of materials for industrial exoskeletons, paving the way for affordable consumer-grade models.
What to Watch in Next-Generation Augmentation
Over the next three to five years, the wearable robotics industry will pivot from rigid external armors toward subtle, textile-integrated systems often called "exosuits." Constructed from flexible elastomeric materials, shape-memory alloys, and pneumatic artificial muscles, these lightweight suits can be worn directly under standard work uniforms.
Key indicators to track include the integration of real-time AI gait prediction models, regulatory updates establishing safety standards for augmented manual labor, and commercial breakthroughs in soft-actuation technology. As battery weights decrease and control loops become truly predictive, powered physical assistance will transition from specialized industrial equipment into everyday functional wear.
Reporting reference: this briefing is TechWire’s independent analysis. Primary reporting was published by Ars Technica — read the source article.
Related analysis
Apple Wallet Pass Designer Streamlines Custom Pass Development
Apple Wallet Pass Designer gives developers native visual editing, semantic data integration, and real-time previews across iOS and watchOS.
3D Movies Smart Glasses: How Wearables Revive Stereo Cinema
Discover how 3D movies smart glasses and VR headsets solve legacy display flaws, powering a stereoscopic streaming resurgence across platform ecosystems.
Google AI Search Intent Failures Highlight Search Decay
Analyze how Google AI search intent failures and unsolicited empathetic AI responses are altering information retrieval and user trust in web search.